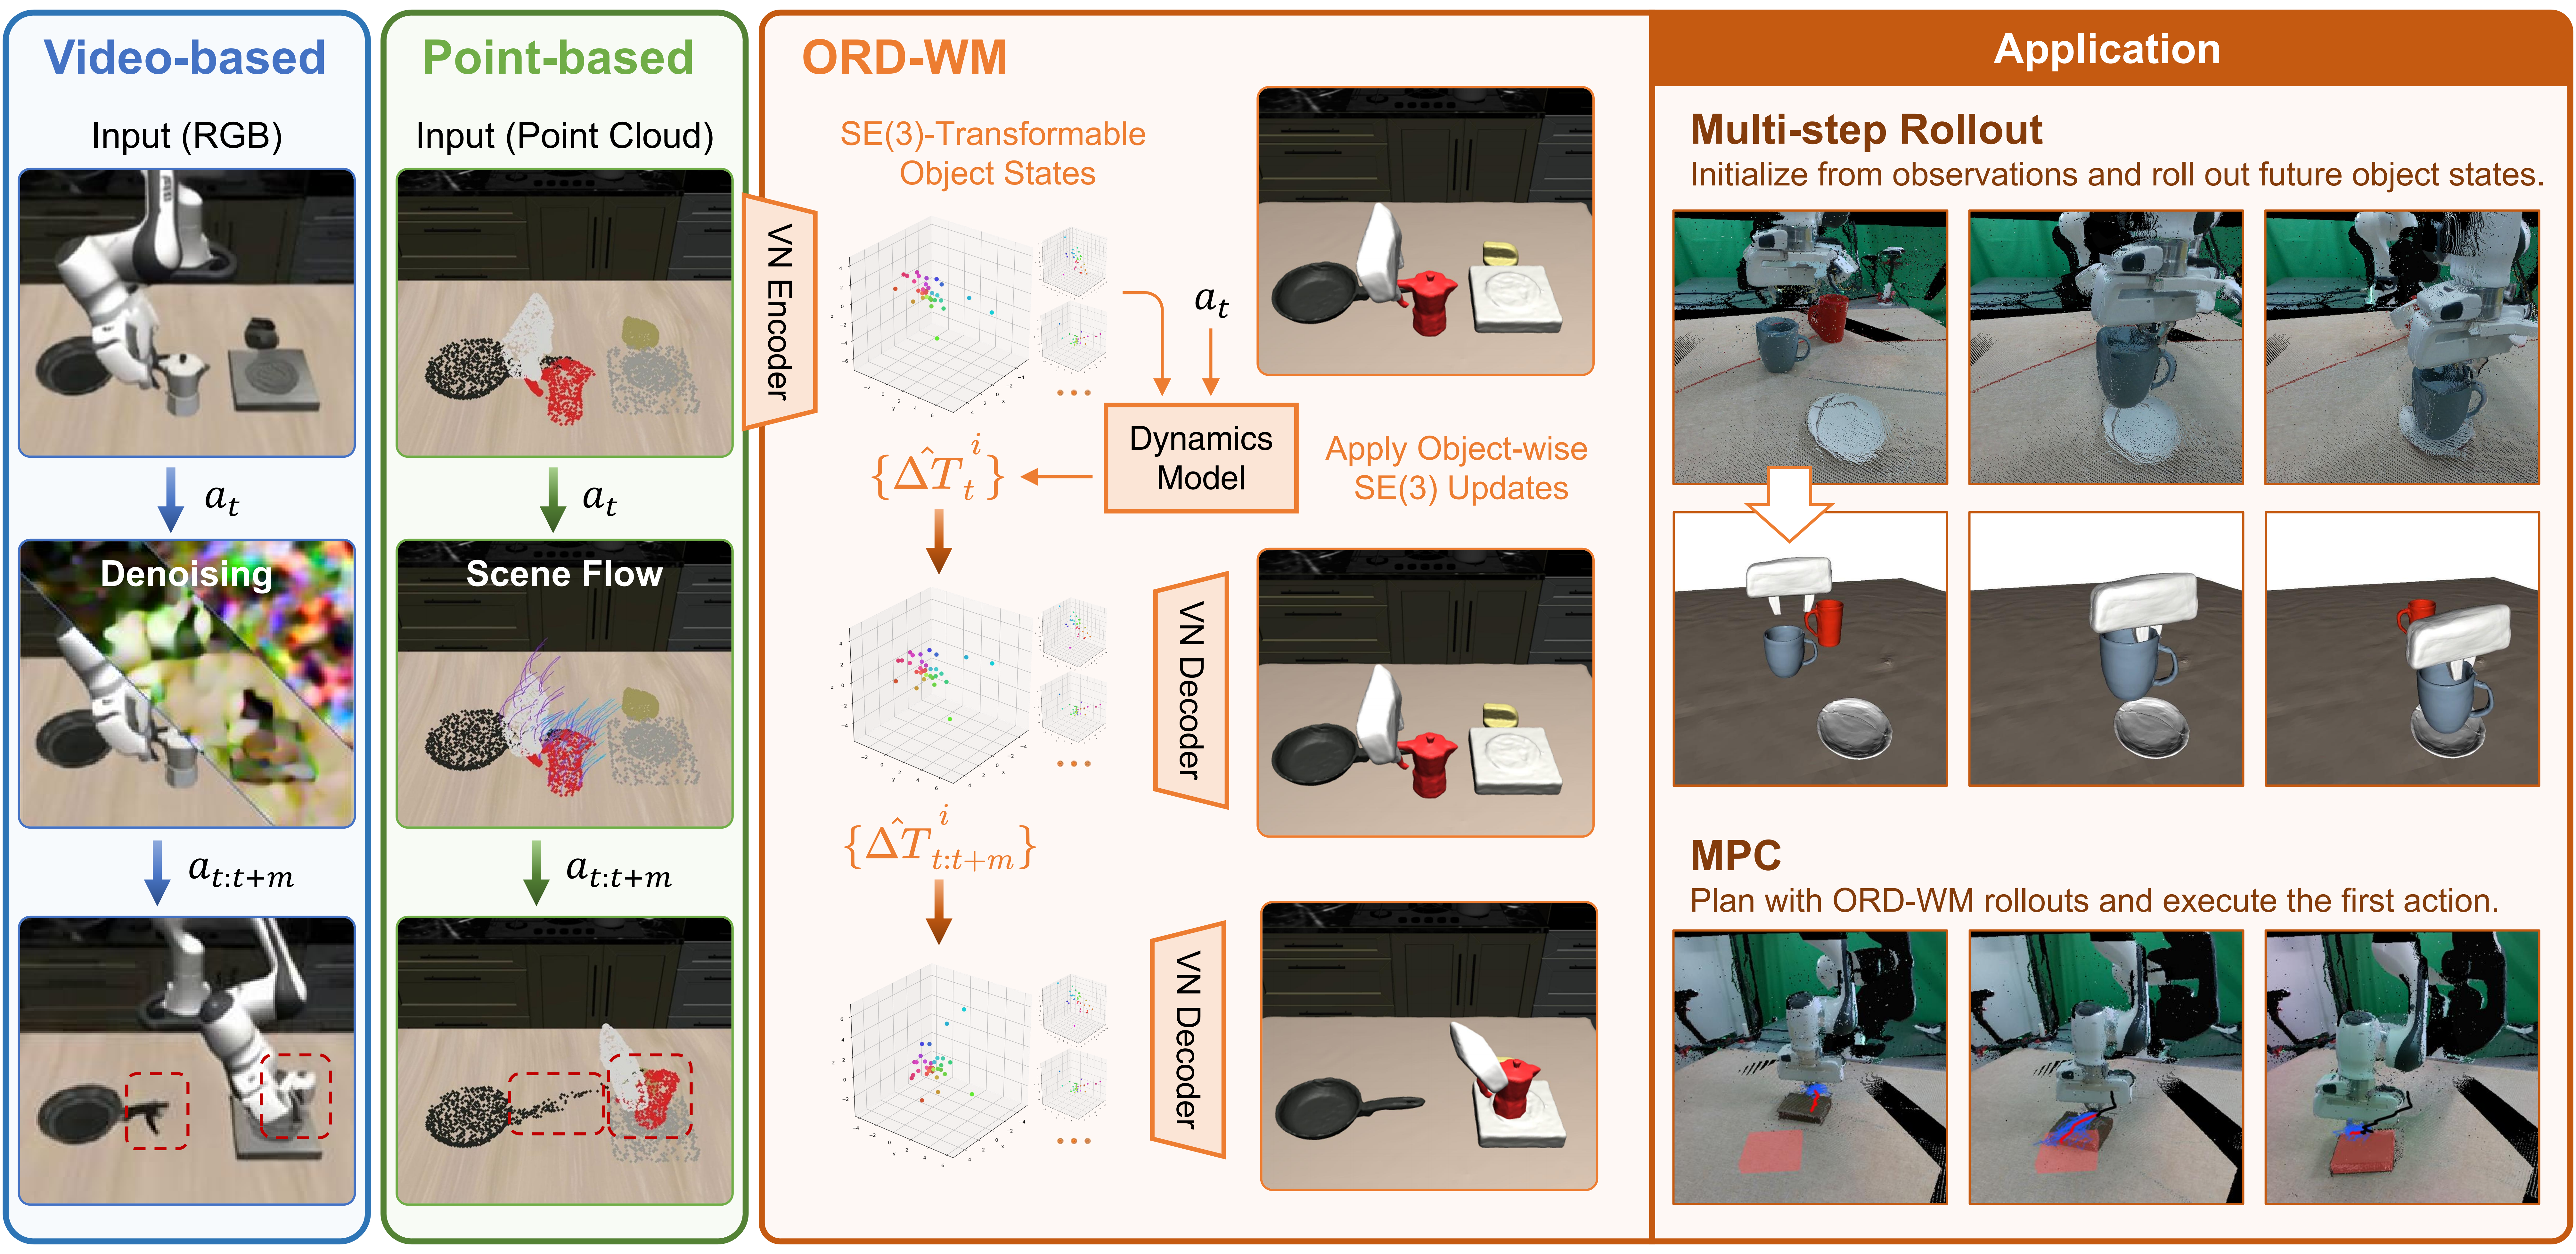
World models provide robots with a predictive mechanism for reasoning about how actions change object states in manipulation tasks. However, existing image-based and dense 3D world models do not explicitly impose object-level rigid motion, leaving rigid-object geometry preservation to be learned implicitly and making multi-step rollouts susceptible to shape drift or object-level motion inconsistency. To address this, we propose ORD-WM, a 3D world model that learns object-centric rigid dynamics for robotic manipulation. ORD-WM learns a vector-neuron variational autoencoder supervised by signed distance fields, which encodes each object point cloud as a geometry-aware latent representation composed of 3D vector features, and uses an action-conditioned dynamics model to predict object-wise SE(3) motion increments. Rather than generating unconstrained next latent states, ORD-WM analytically applies predicted object-wise rigid transformations to the current latent states, separating persistent object geometry from pose changes. Experiments show that ORD-WM enables stable, geometry-preserving multi-step prediction and supports efficient real-time replanning for closed-loop model predictive control in simulated and real-world manipulation scenarios. More details and videos are available at: https://anonymous.4open.science/w/ORD-WM/.
Initialize from observations and roll out future object states without re-observation.
Plan with ORD-WM rollouts and execute the first action.
@article{anonymous2026ordwm,
  author    = {Anonymous Authors},
  title     = {ORD-WM: Learning Object-Centric Rigid Dynamics for 3D World Modeling in Robotic Manipulation},
  year      = {2026},
}